What we tested against, exactly
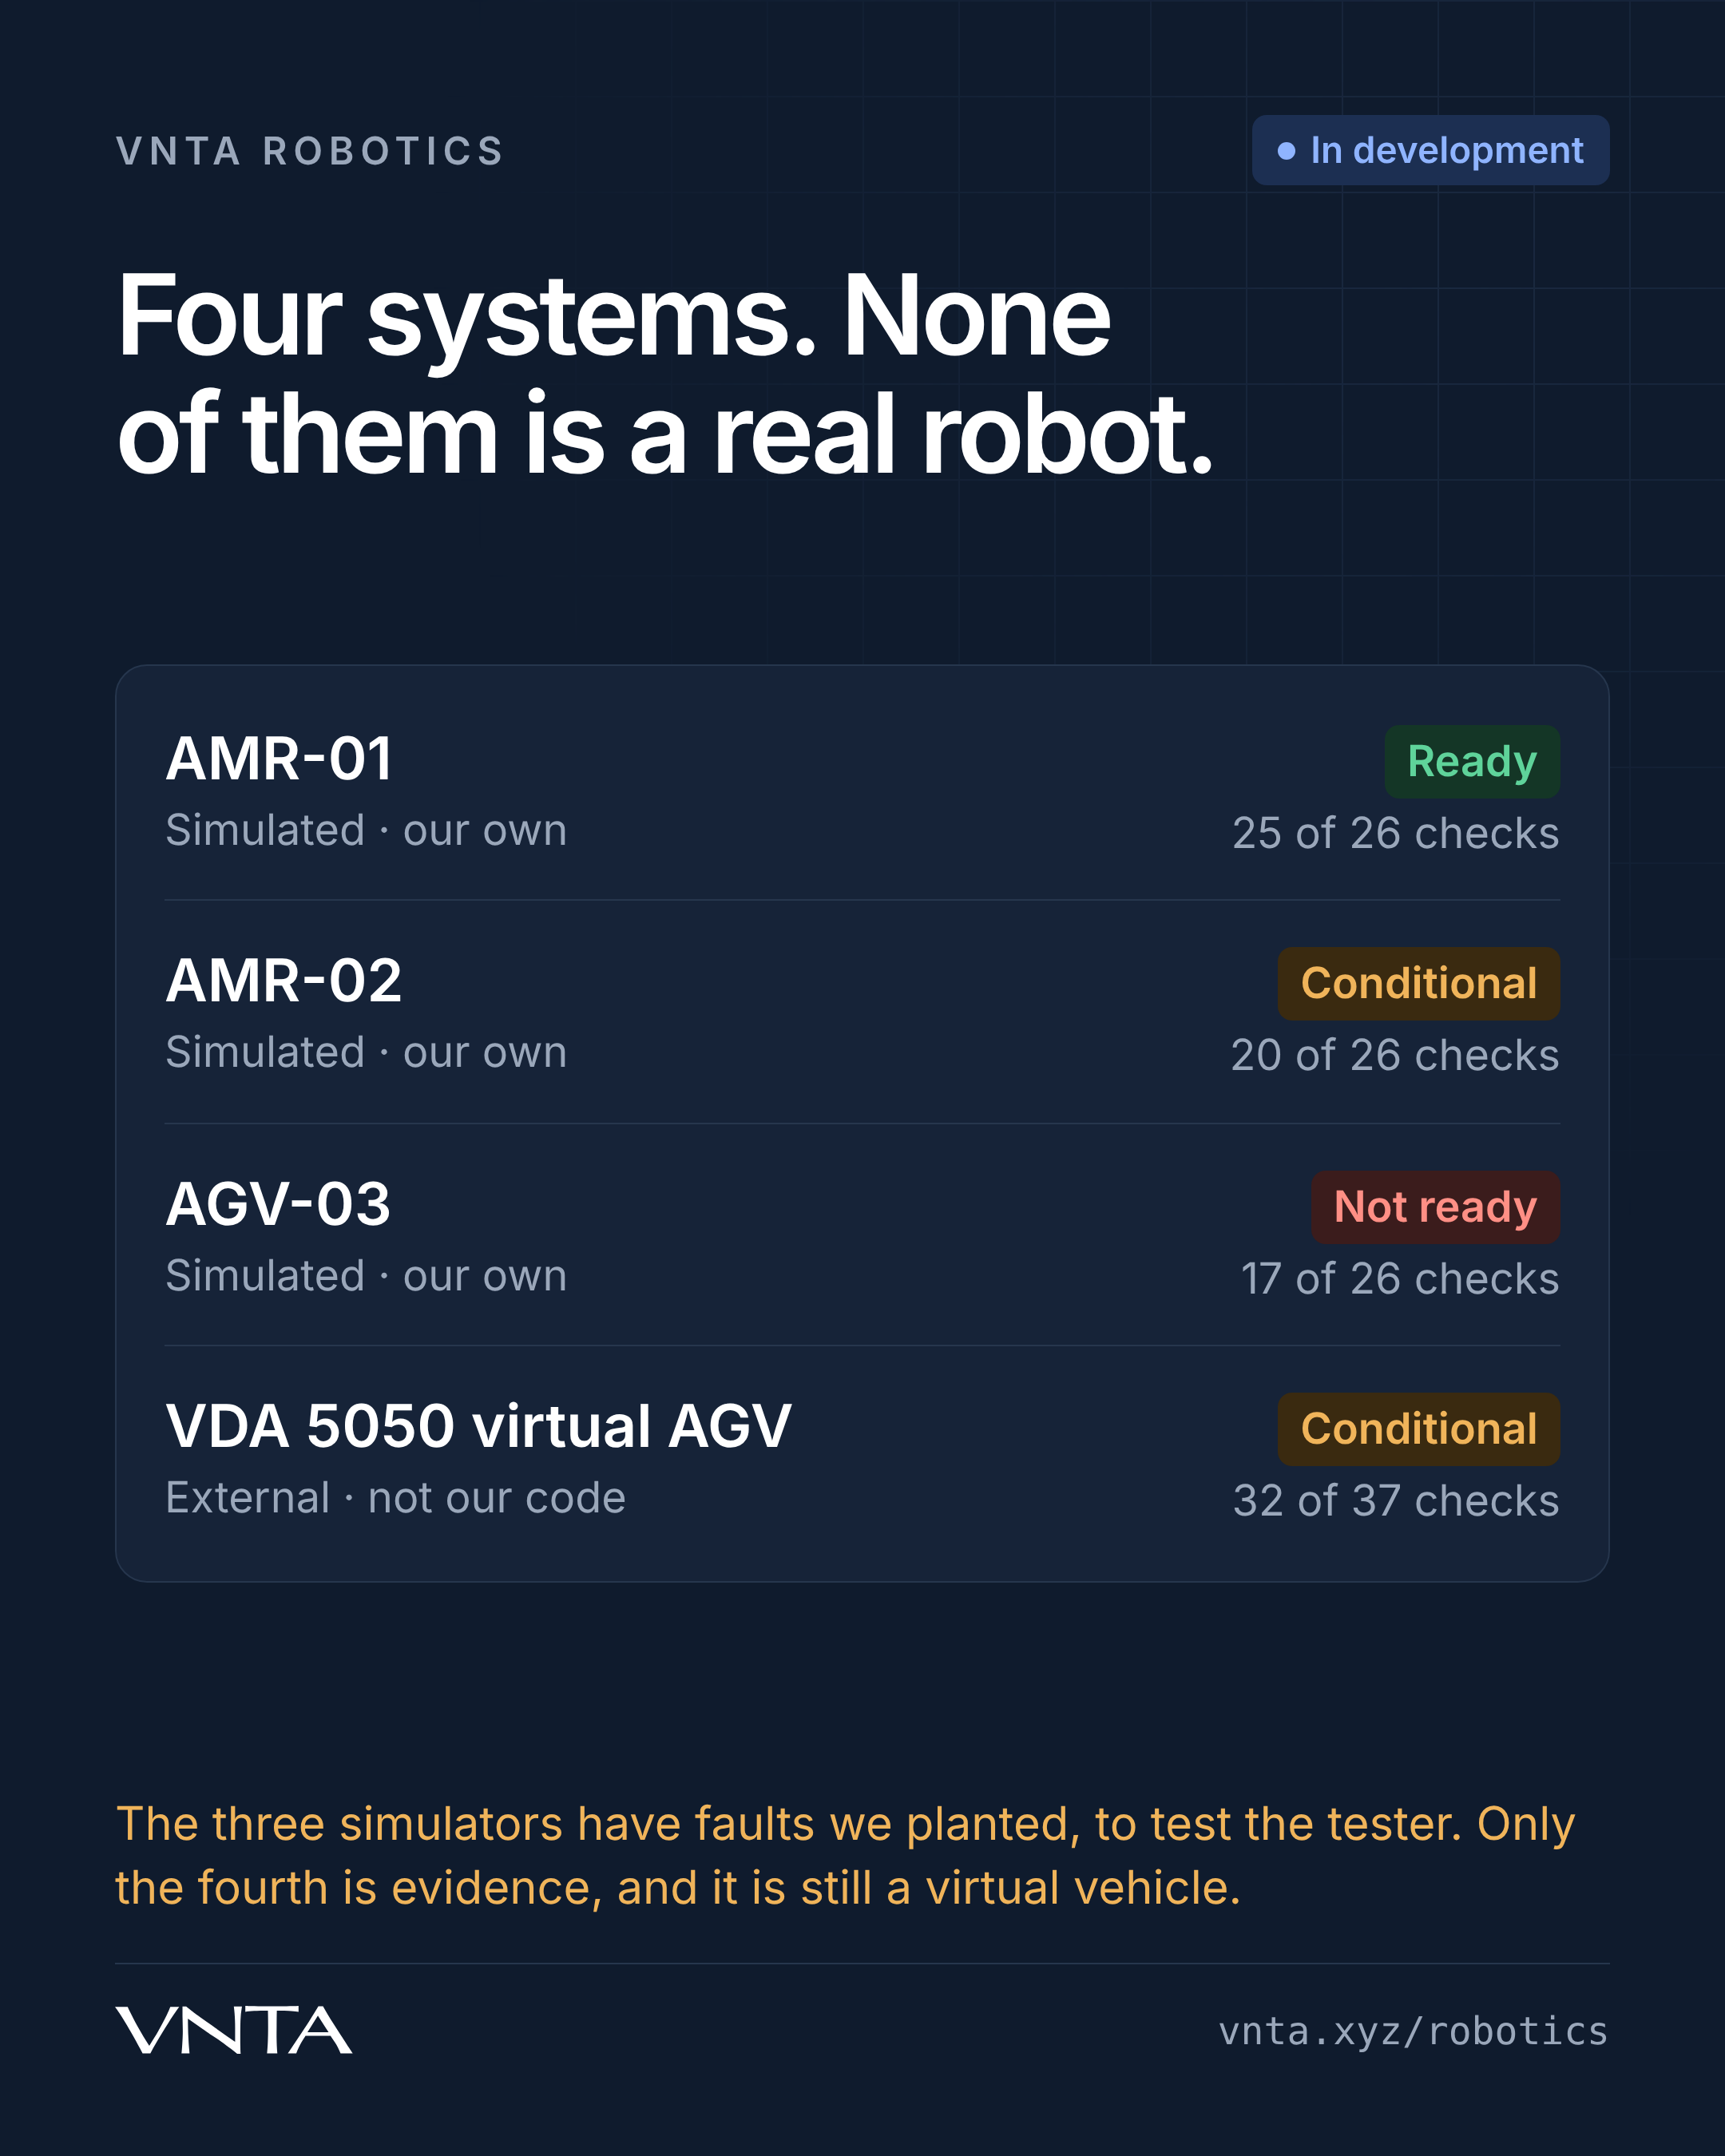
We have tested our robot validation software against four systems. None of them is a real robot. Here is exactly what they are.
Three are simulators we wrote ourselves. Each speaks a different invented interface, and each has faults we planted on purpose. One has no pause. One acts on the same order twice. One goes quiet after a restart.
The suite finds every planted fault and no others. That proves the tester works. It proves nothing about robots.
The fourth is the one that matters: an open-source VDA 5050 virtual vehicle that somebody else wrote. We ran it unmodified, in its own process, and judged its messages against the official schemas.
32 of 37 checks passed. Every behavioural check passed: orders, pause, resume, cancel, duplicates, charging, recovery after a restart.
The next step is a real system. That needs a partner who has one.
Validation has been tested against simulated systems and one external VDA 5050 implementation. It has not yet been run against a real robot. We are now taking on our first production design partners. VNTA validation evaluates software integration behaviour against a chosen set of checks. It is not a functional-safety certification and does not replace manufacturer commissioning procedures.
Also posted on Bluesky.