The one question
What can this robot actually do, and do we have evidence that it works?
That question is harder to answer than it should be.
A robot’s interface says it supports pause. The fleet manager says it speaks the standard. Then you get on site, and pause does something slightly different from what the manual said.
We are building software that answers the question properly. It connects to a robot or fleet system, runs the same set of checks against it, and keeps the evidence: every call, every answer, every raw message.
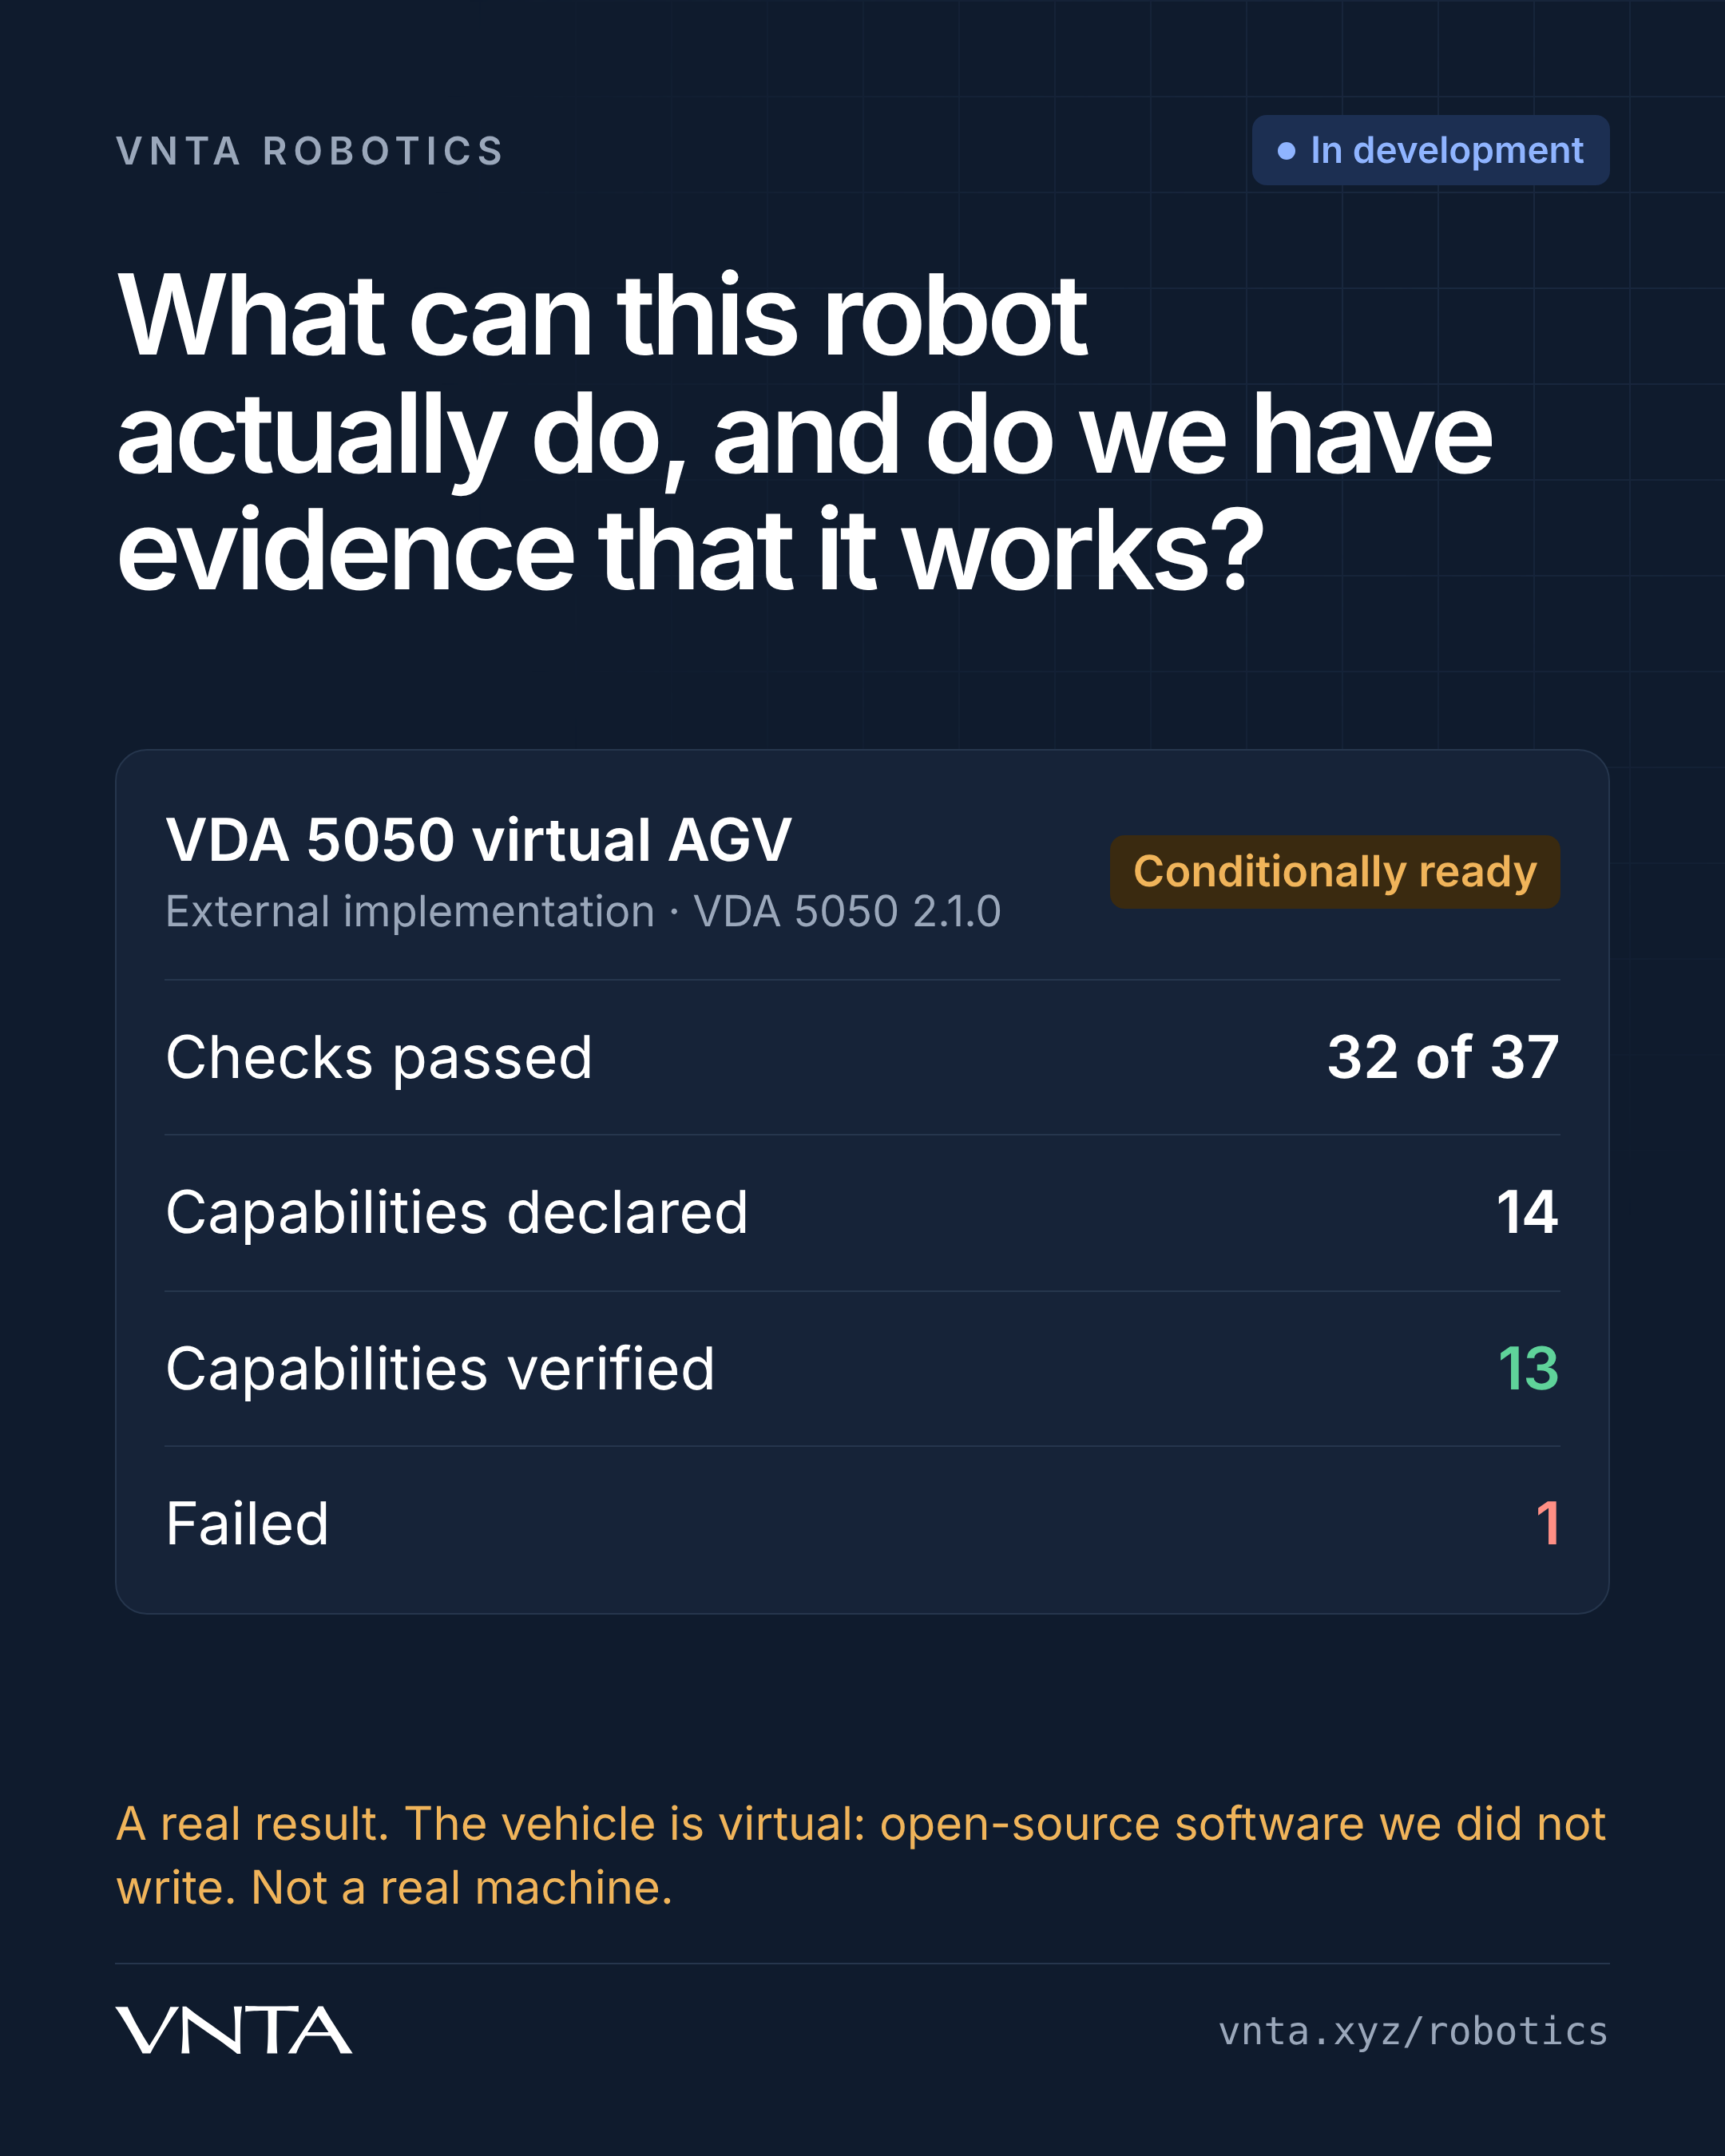
It is called VNTA Robotics. It is in development. So far it has run against simulated robots and one virtual vehicle that we did not write. It has not met a real machine yet.
Over the next few weeks we will post what we have built, what it found, and what is not done.
If you commission mobile robots for a living, we would like to hear how you do this today.
Validation has been tested against simulated systems and one external VDA 5050 implementation. It has not yet been run against a real robot. We are now taking on our first production design partners. VNTA validation evaluates software integration behaviour against a chosen set of checks. It is not a functional-safety certification and does not replace manufacturer commissioning procedures.